Turret Tool Changer
Adapting the DM3300 Turret Controls to run on the Acorn Hardware at first seemed like a daunting task. Once I dug into the individual components of the turret system it seemed like integrating the existing hardware would be a lot easier than I initially thought.
The hardware that needed to be integrated was:
Turret Home (#1) Position Sensor
Turret Position Encoder
Turret Stepper Motor
Turret Extend
Turret Lock
Electronics Recap:
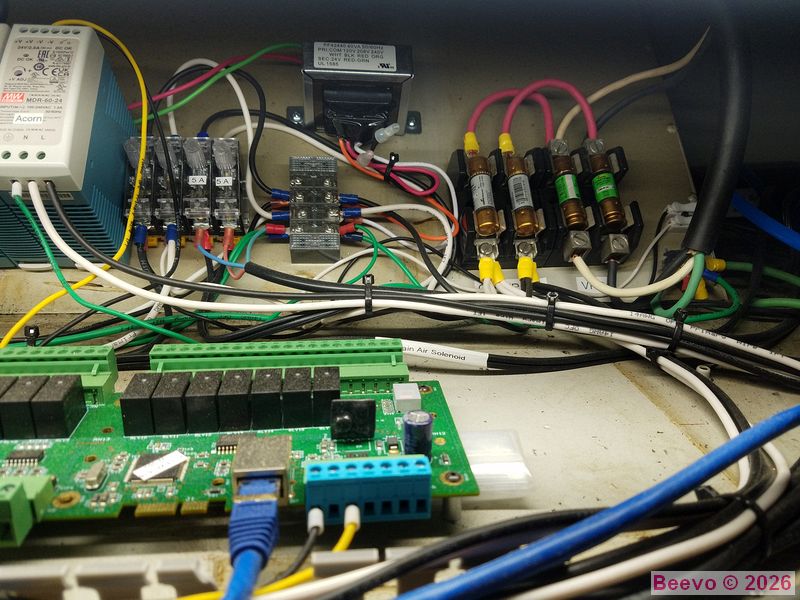
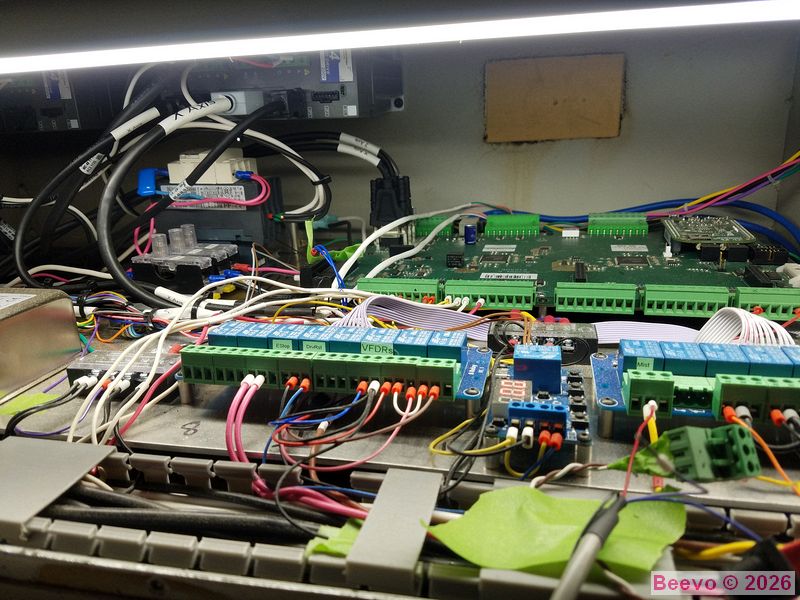
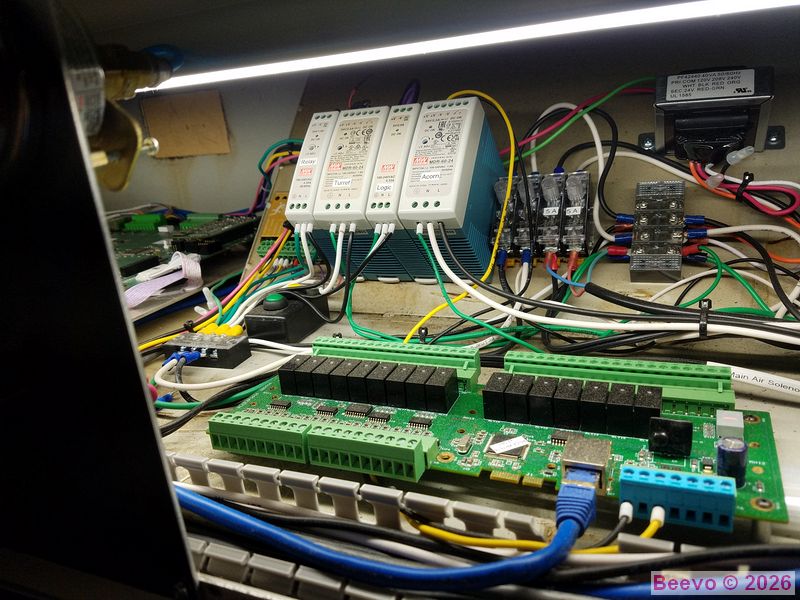
This spread shows (starting from upper left) the DMM Dyn4 AC Servo Drives (top of cabinet) the Acorn 6 Controller (rear of cabinet) with the two 8 channel Relay Modules (front of cabinet), The Centroid Ether1616 I/O Expansion Board (front) with the Fuses/Power Supplies on the sloped panel behind.
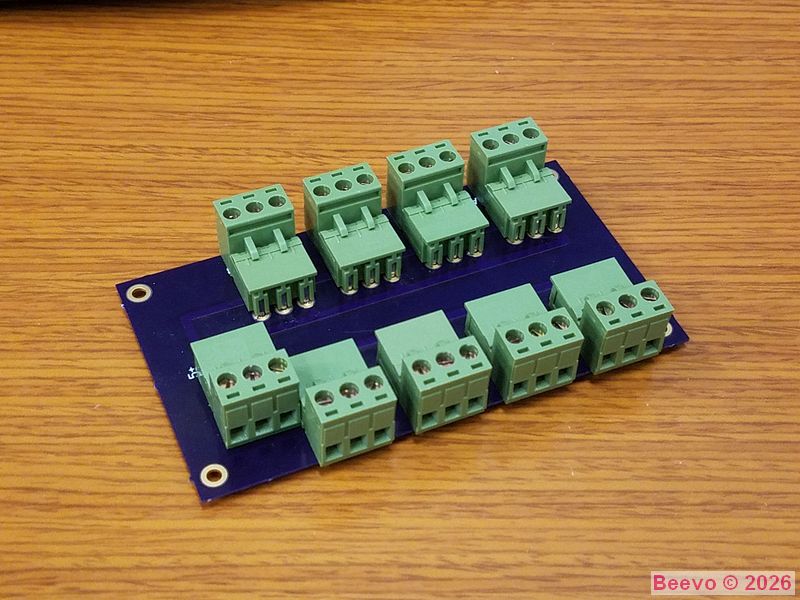
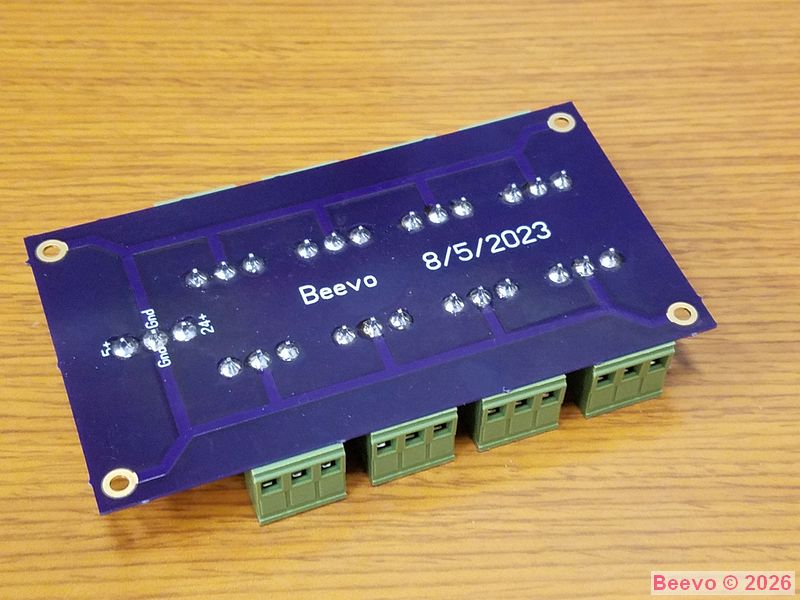
I designed and had made a circuit board using Phoenix connectors to facilitate distribution of the Powers (5v & 24v DC) and Grounds for the various boards and modules in the unit.
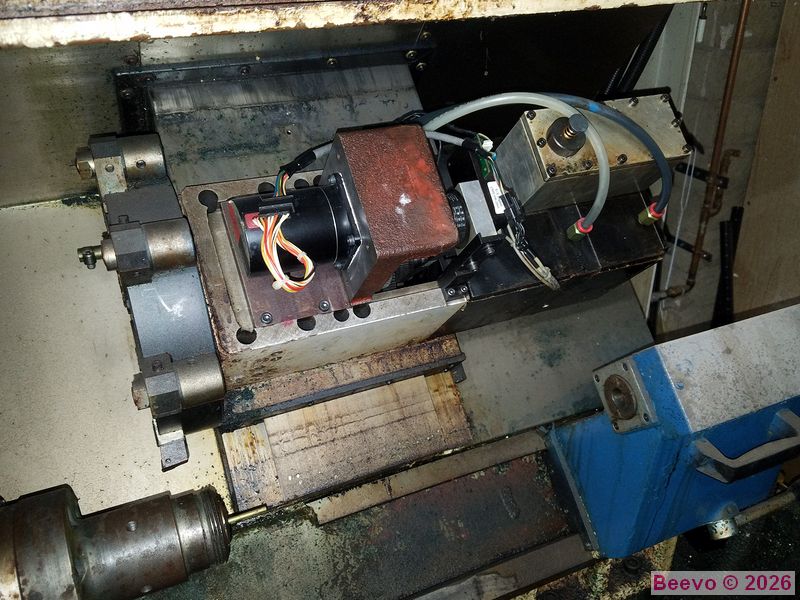
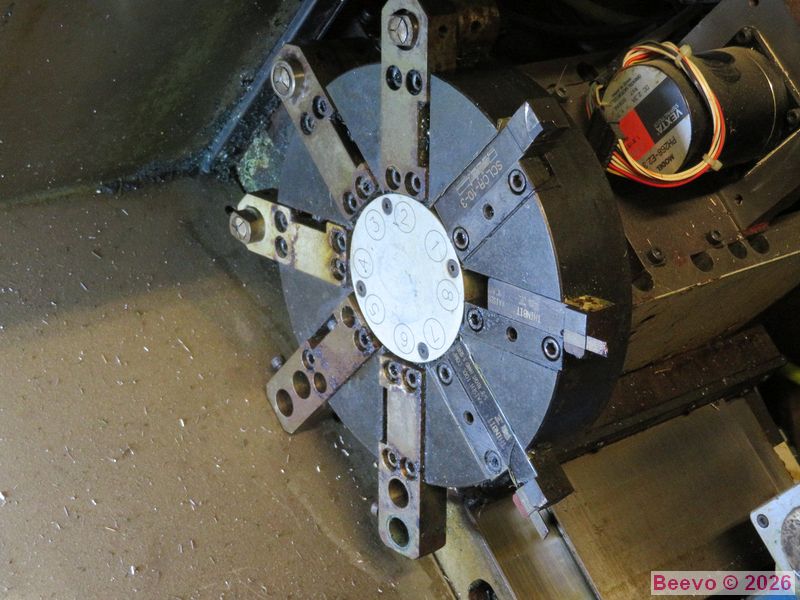
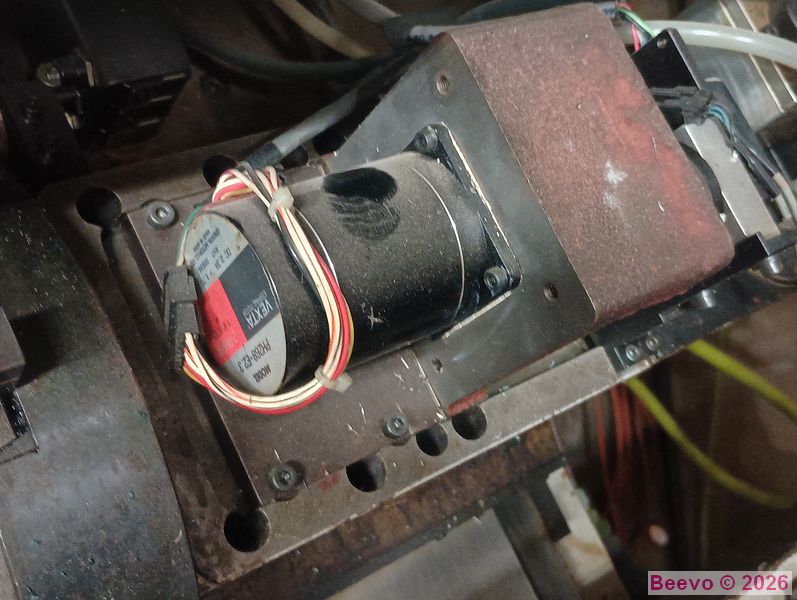
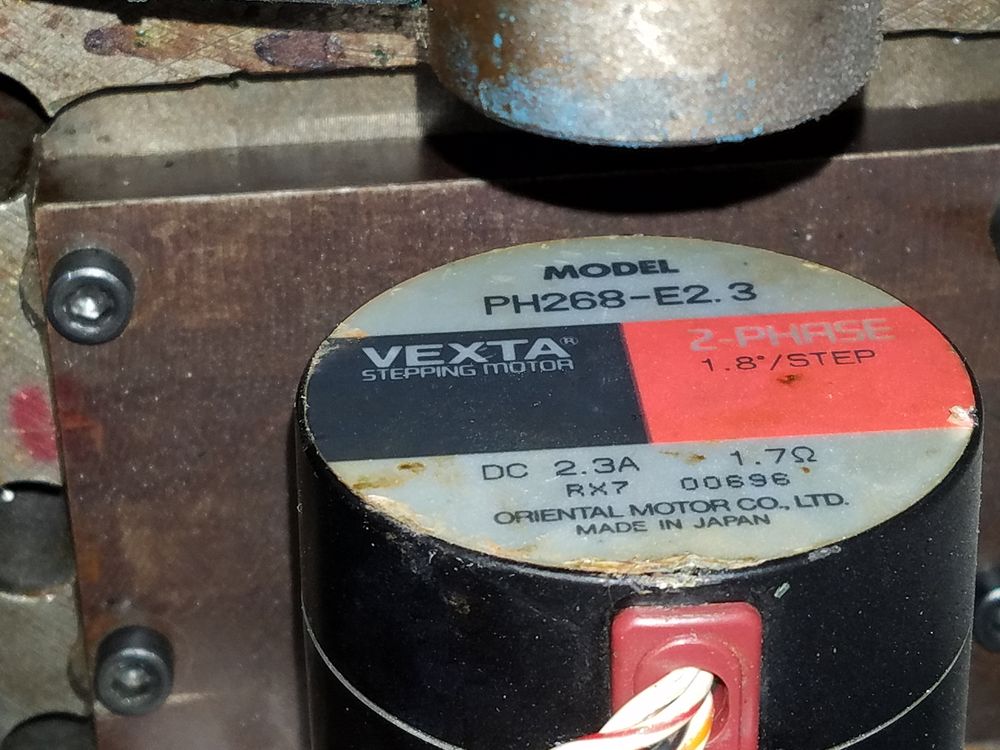
The tool changer has eight tool positions and uses a Curvic Coupling to lock the turret into place. The turret uses a pretty standard Vexta Stepper Motor which is geared 1:1 with the turret shaft. An optical encoder is also connected 1:1 with the turret shaft.
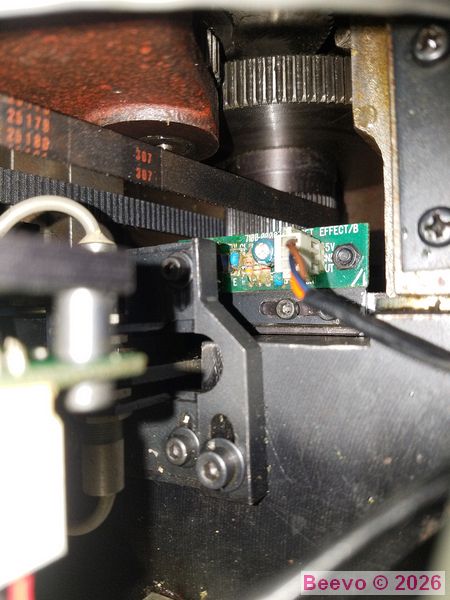
The two gears at the top of the image are stepper drive shaft (top) and turret shaft bottom. The timing belt is the drive for the shaft encoder.
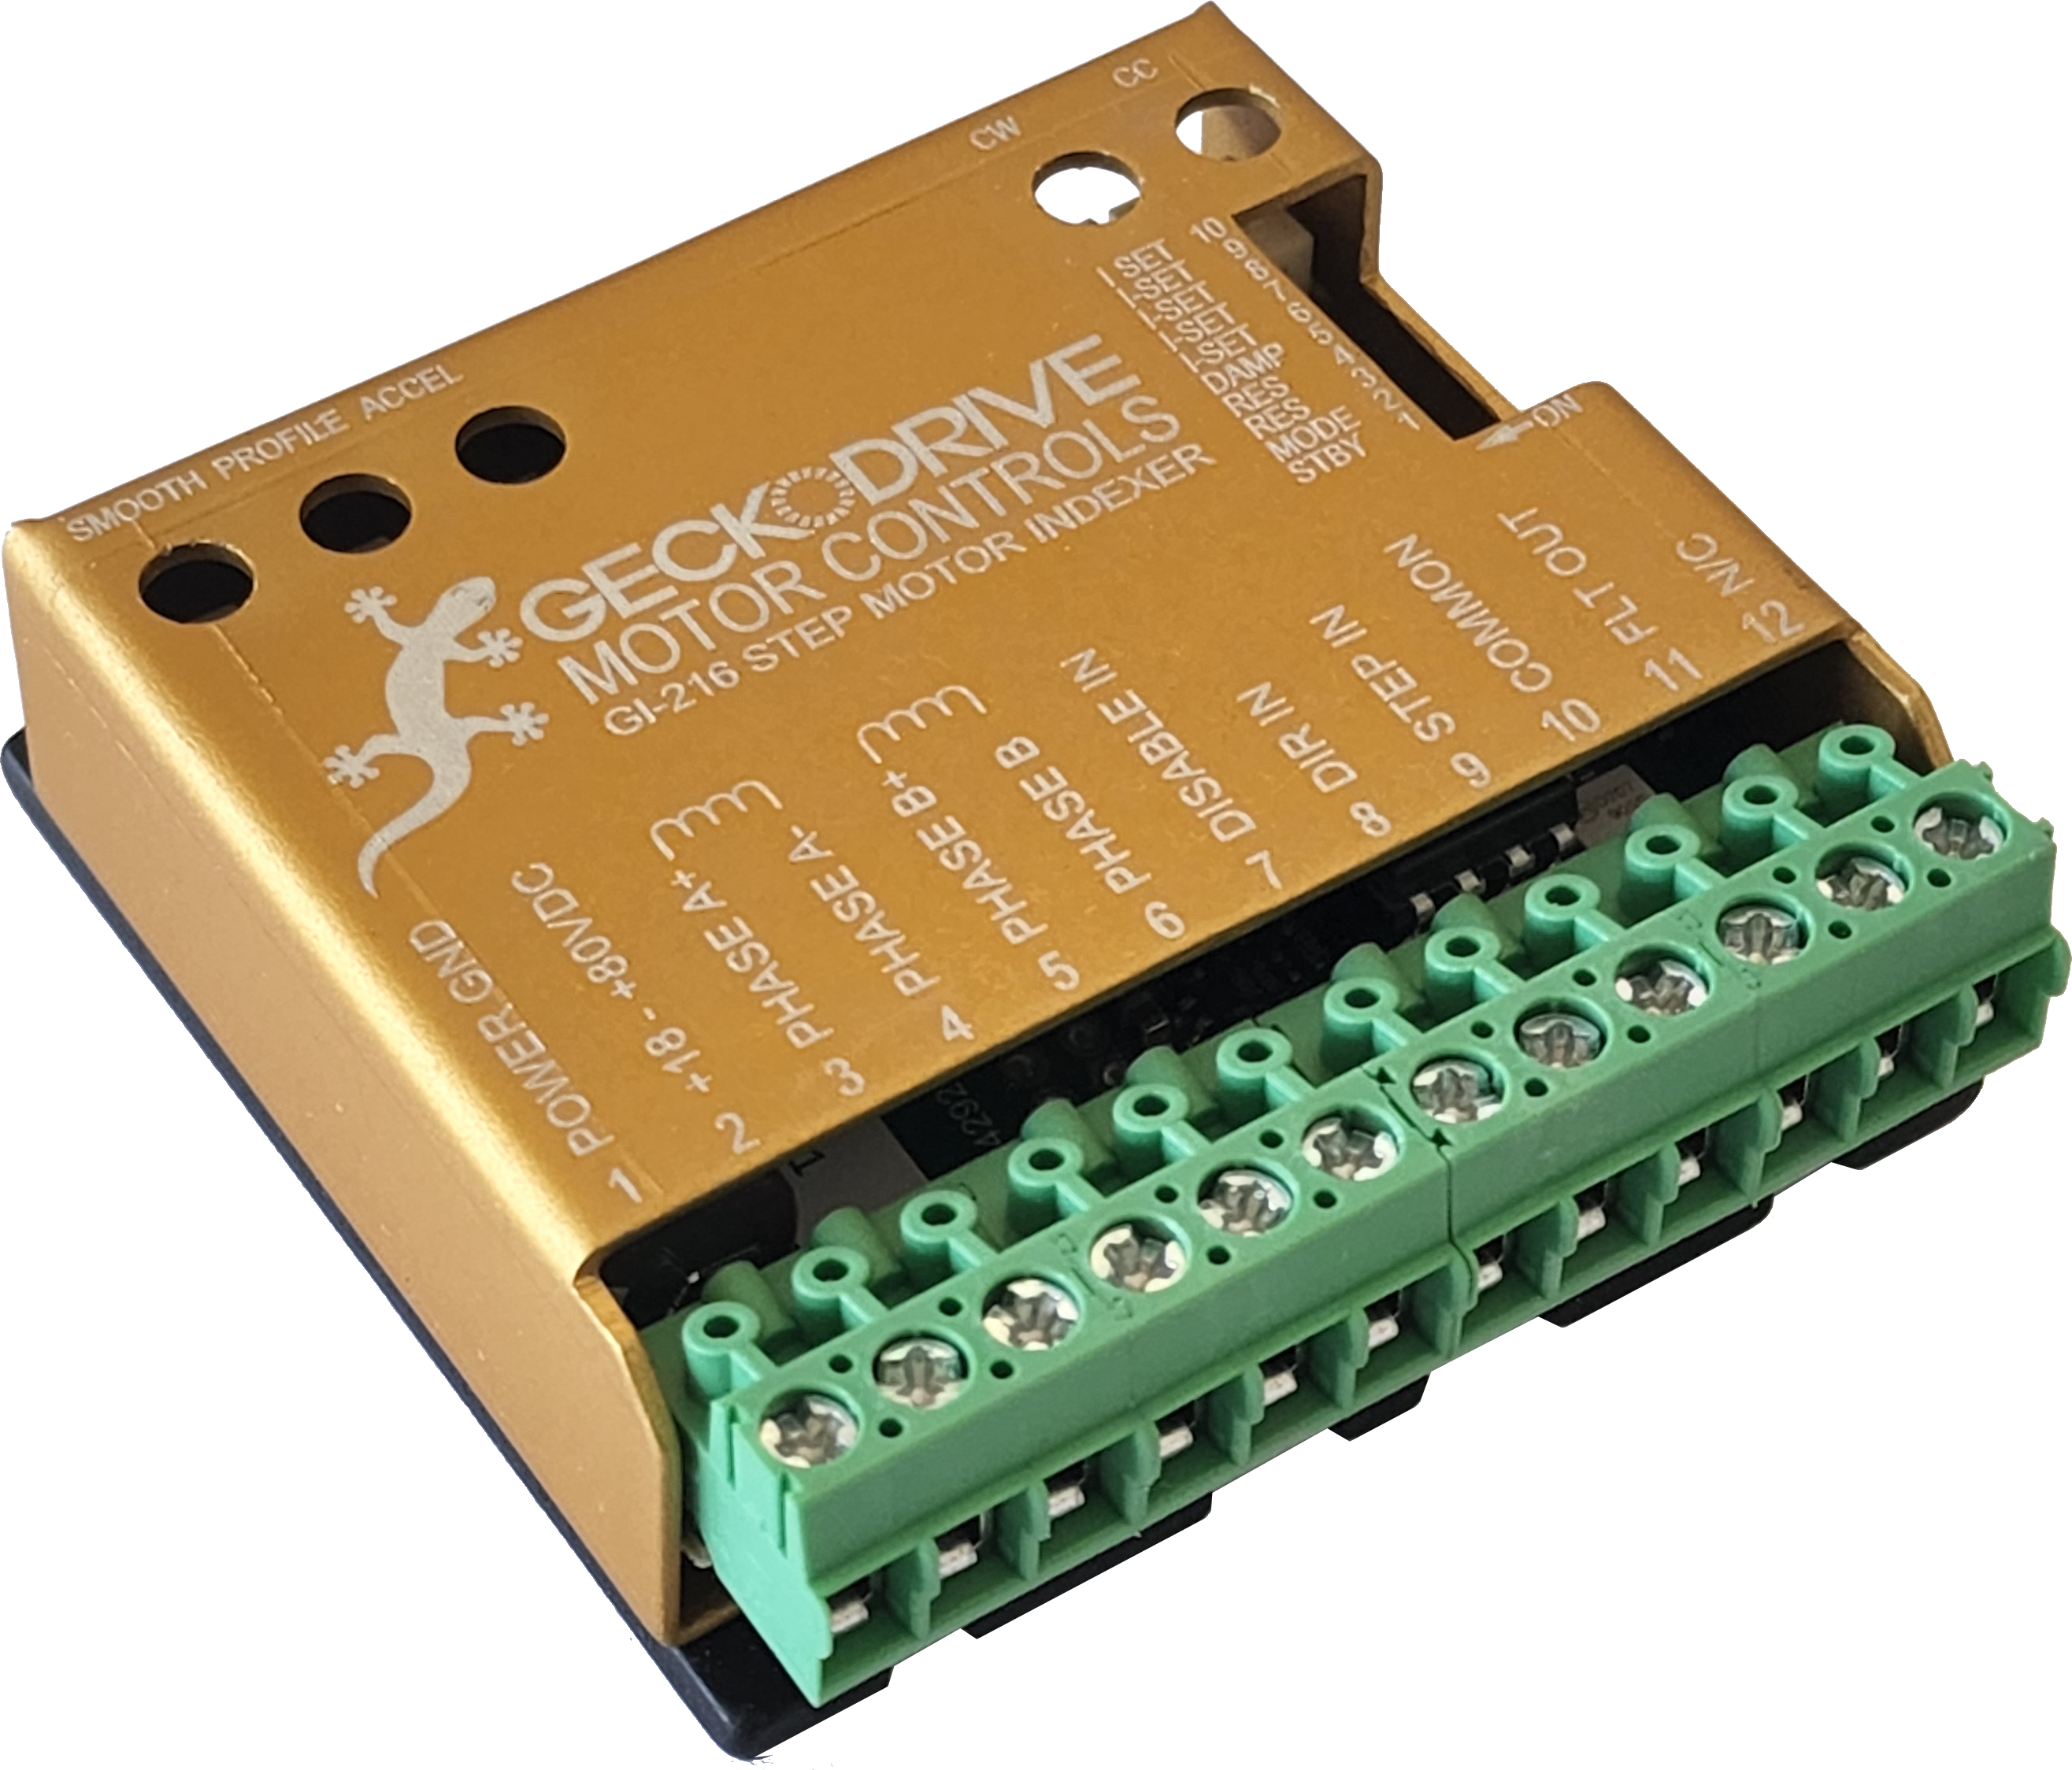

Controlling the motor I elected to use a Gecko G216 Stepper Controller which can be set to run the stepper like a normal motor (no step/direction control needed). The drive is located to the left of the power supply bank in the right image. The push button box was a temporary manual control used while testing the turret components.
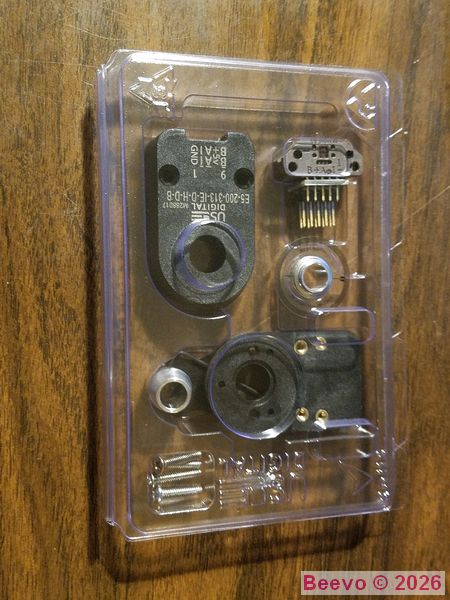
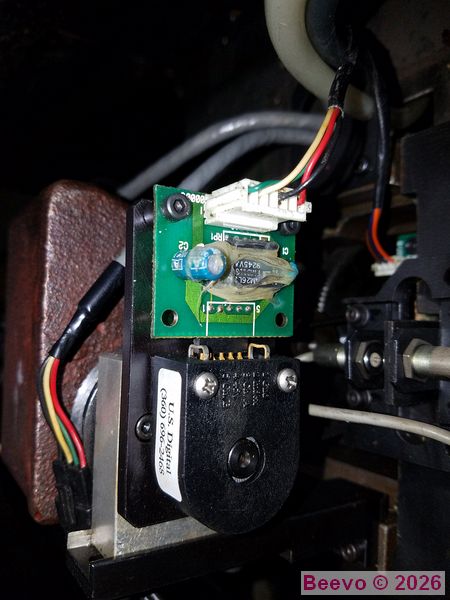
On the left a shot of the new encoder kit. The encoder was changed out to a 200 count encoder (up from the original 100) to give better resolution and counts that are an even division of 8. With quadrature there are 800 counts per revolution and 100 counts between each tool. I figured this would simplify the math when it came time to program the system.
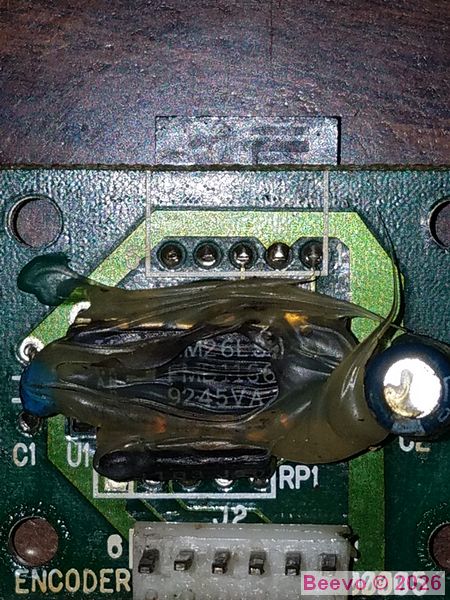
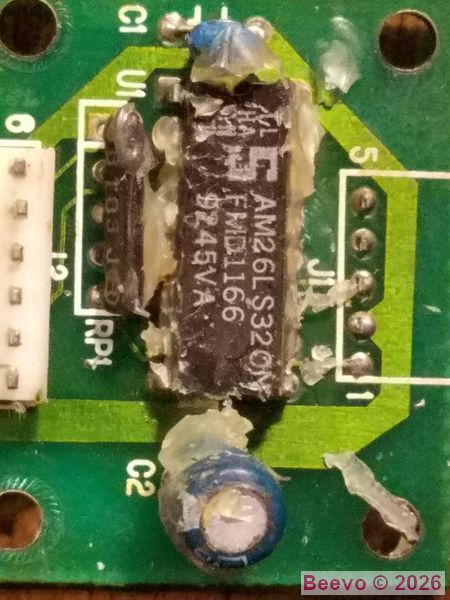
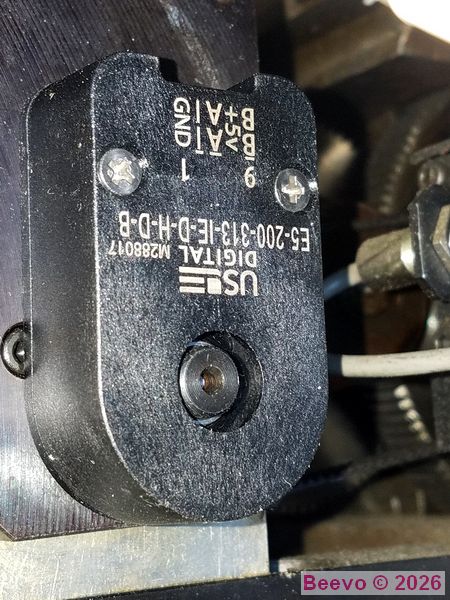
The original encoder interface board on the left. I removed some of the potting so I could see the part number of the interface chip to verify the system. Nothing needed to be changed as it wound up being a pretty much standard interface circuit. Newly Installed encoder on right.
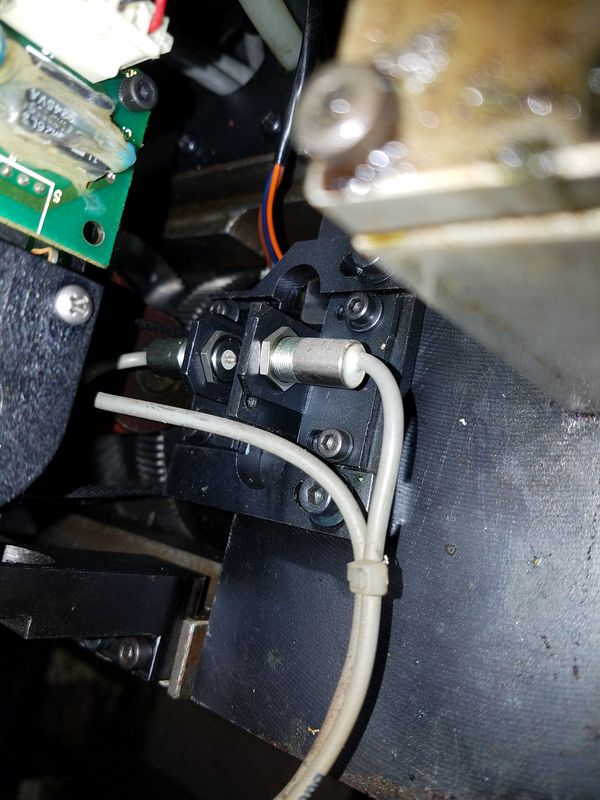
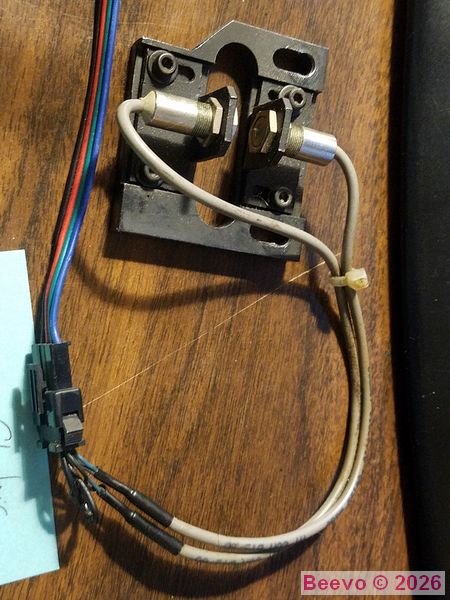
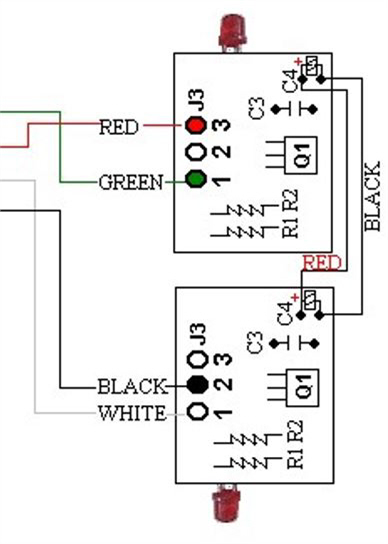
Next up was to get the Turret In/Out and Locking Mechanism running. On the left we see the installed Proximity Sensor set. Close up of the MY-COM B75/80 Proximity Sensor assembly. The good news is the setup could be used as-is by the Acorn6
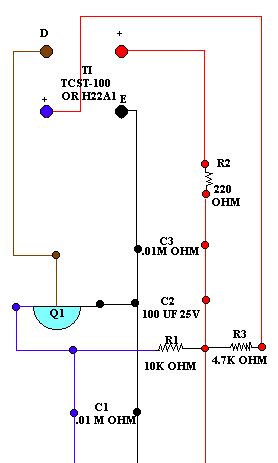
Turret Home Board supporting the Texas Instruments/Vishay/Onsemi TCST-100 optical slot phototransistor shown. Like the Turret In/Out Proximity Switches, the Tool #1 sensor and control board was supported as-is with the Acorn6
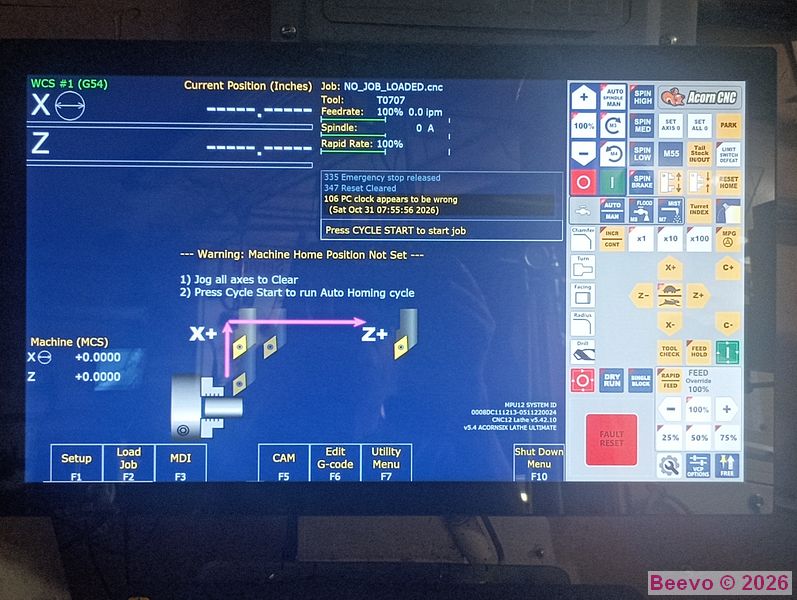
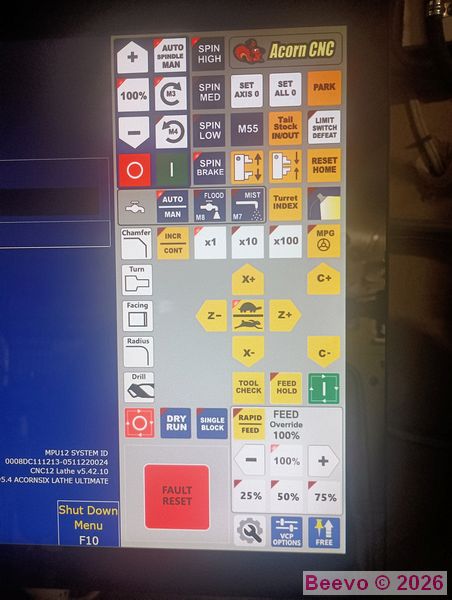
Now that I can Lock/Unlock the Turret the next move was to make it go round and round. A custom PLC was written by Centroid to calculate the position of the Turret and to do the Tool #1 Homing. The PLC saves the last tool position and when the system is restarted there is no need to home to tool #1. I plan to replace the M55 button on the VCP with a button labeled Home to Tool #1 (M18)
With the gearing and quadrature there are 800 counts per revolution yielding 100 pulses per tool. The design of the Curvic Coupling will compensate for any slight "misses" on tooth alignment. In testing the control system has been very accurate, regardless of the direction the turret is turning. The PLC will calculate the shortest distance to the next desired tool and may rotate in reverse to get there. Needless to say I am SUPER impressed with the functionality of the PLC and the Acorn CNC software!
Demonstration Videos:
Multi Tool Change (shows change in either direction, moving to next closest tool)
Air Cutting Demo (Pawn) (long)